Design challenges
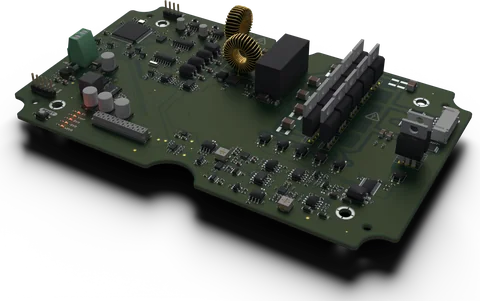
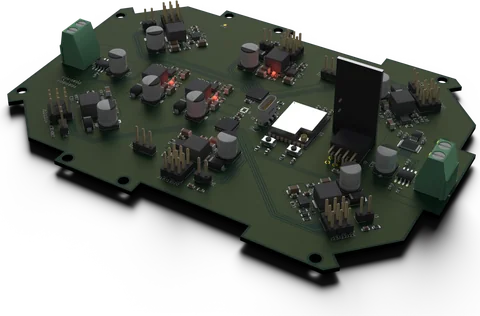
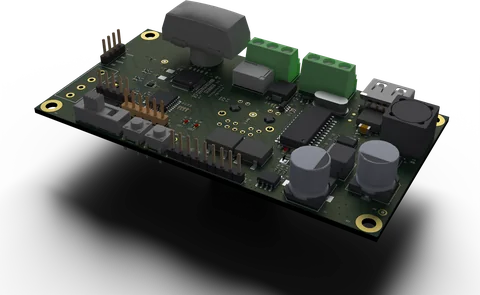
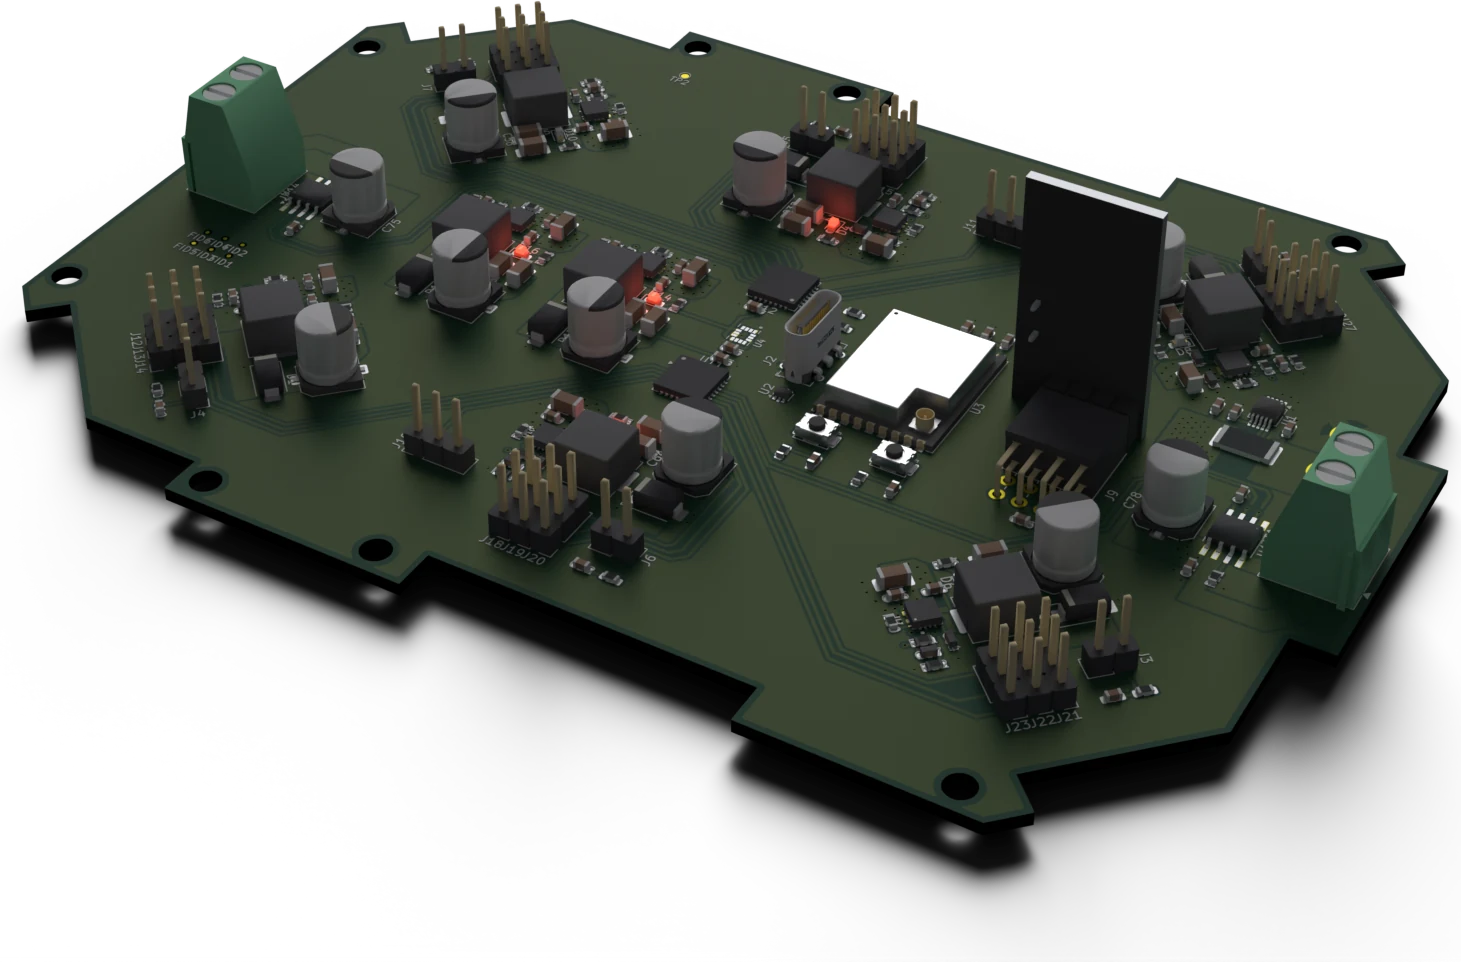
- High current from the battery for 20 servos: eight 6 A buck rails with a TVS on each rail.
- Knowing the robot's real consumption: current and energy metering for the whole system.
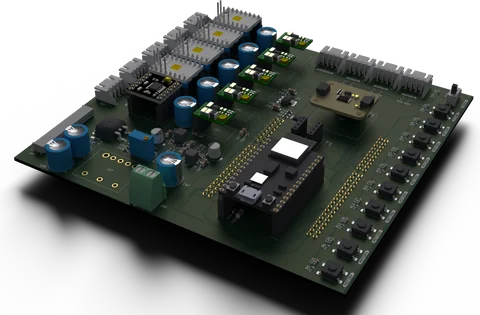
- 20 servos, 6 limit switches and 2 H-bridges from a single MCU: external PWM generators over I²C.